Projects in robot learning, medical AI, 3D vision, and generative modeling.
Collaborative Surgical Robotics
Robot learning · Human–robot collaboration
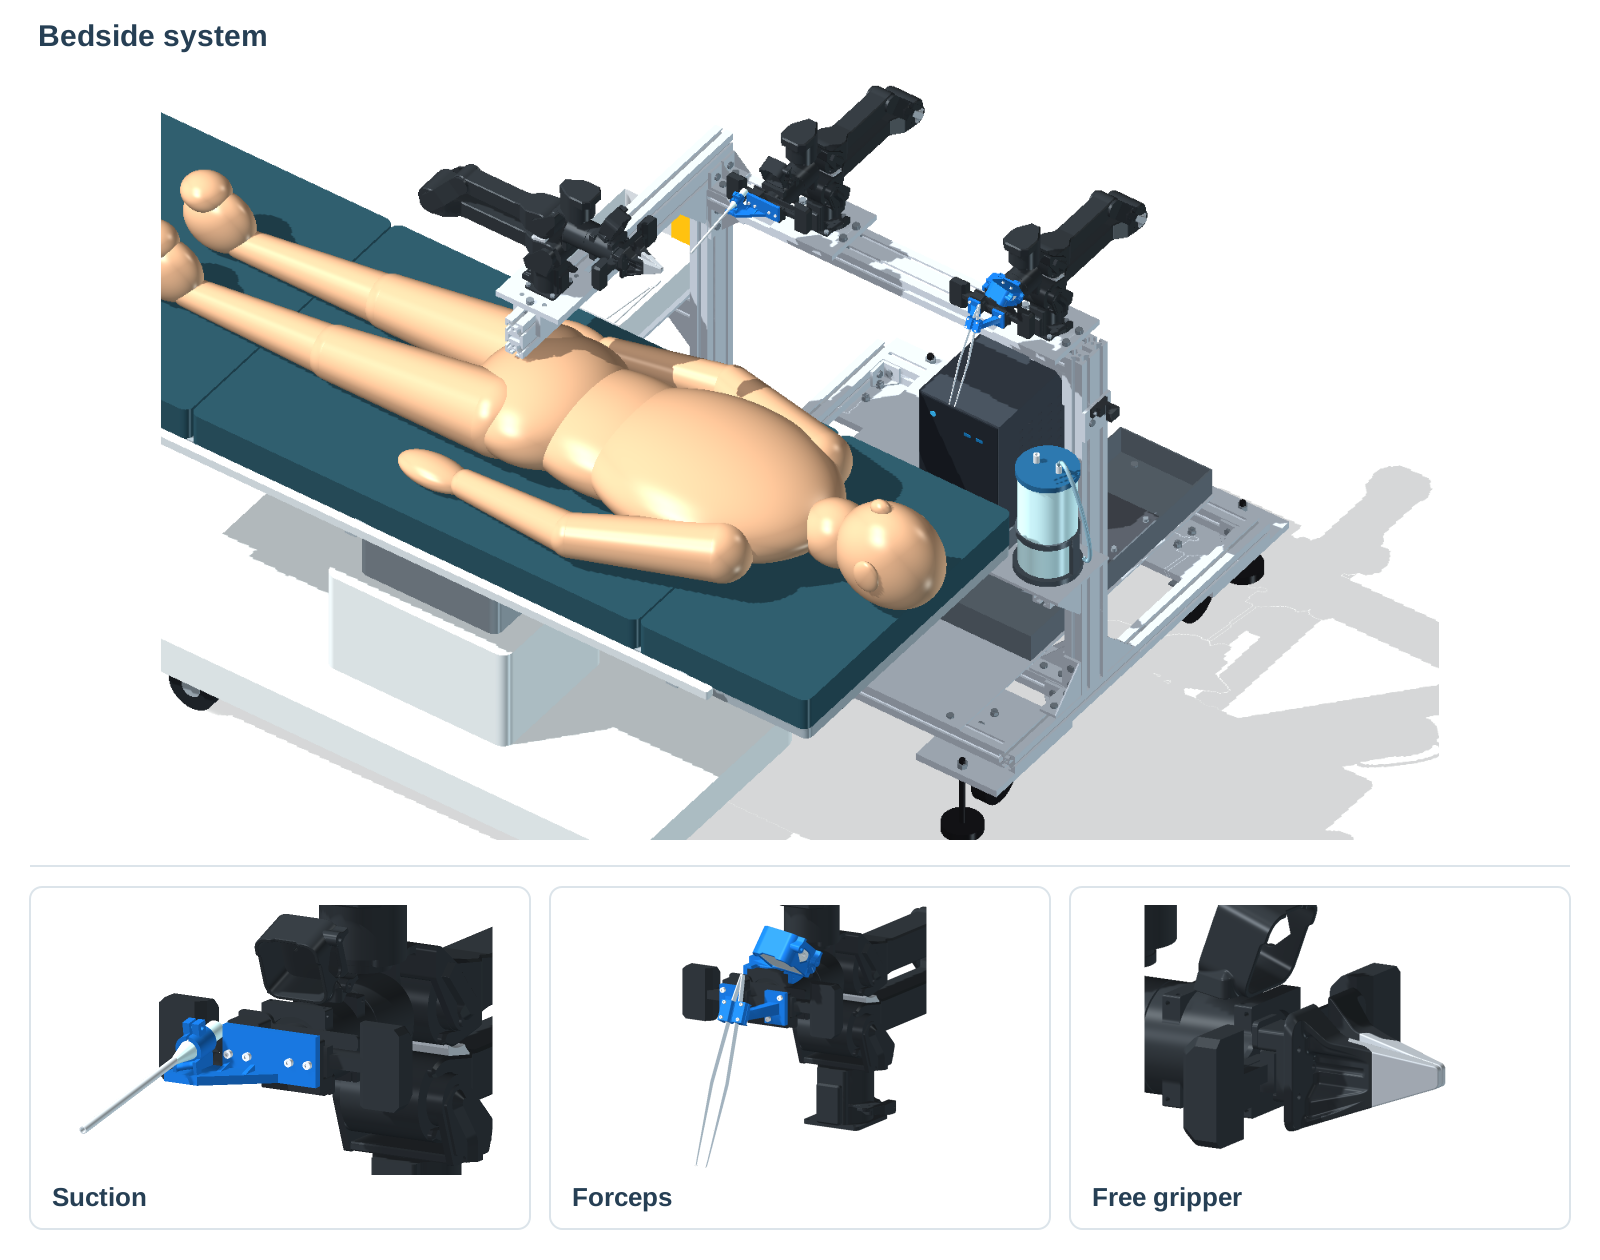
Developing a portable multi-arm assistive system for open surgery, spanning cardiac procedures. The work connects learned manipulation skills, safe handover, and VLM-supervised execution to support surgical teams.
Hierarchical control · Multimodal perception · 3D reconstruction
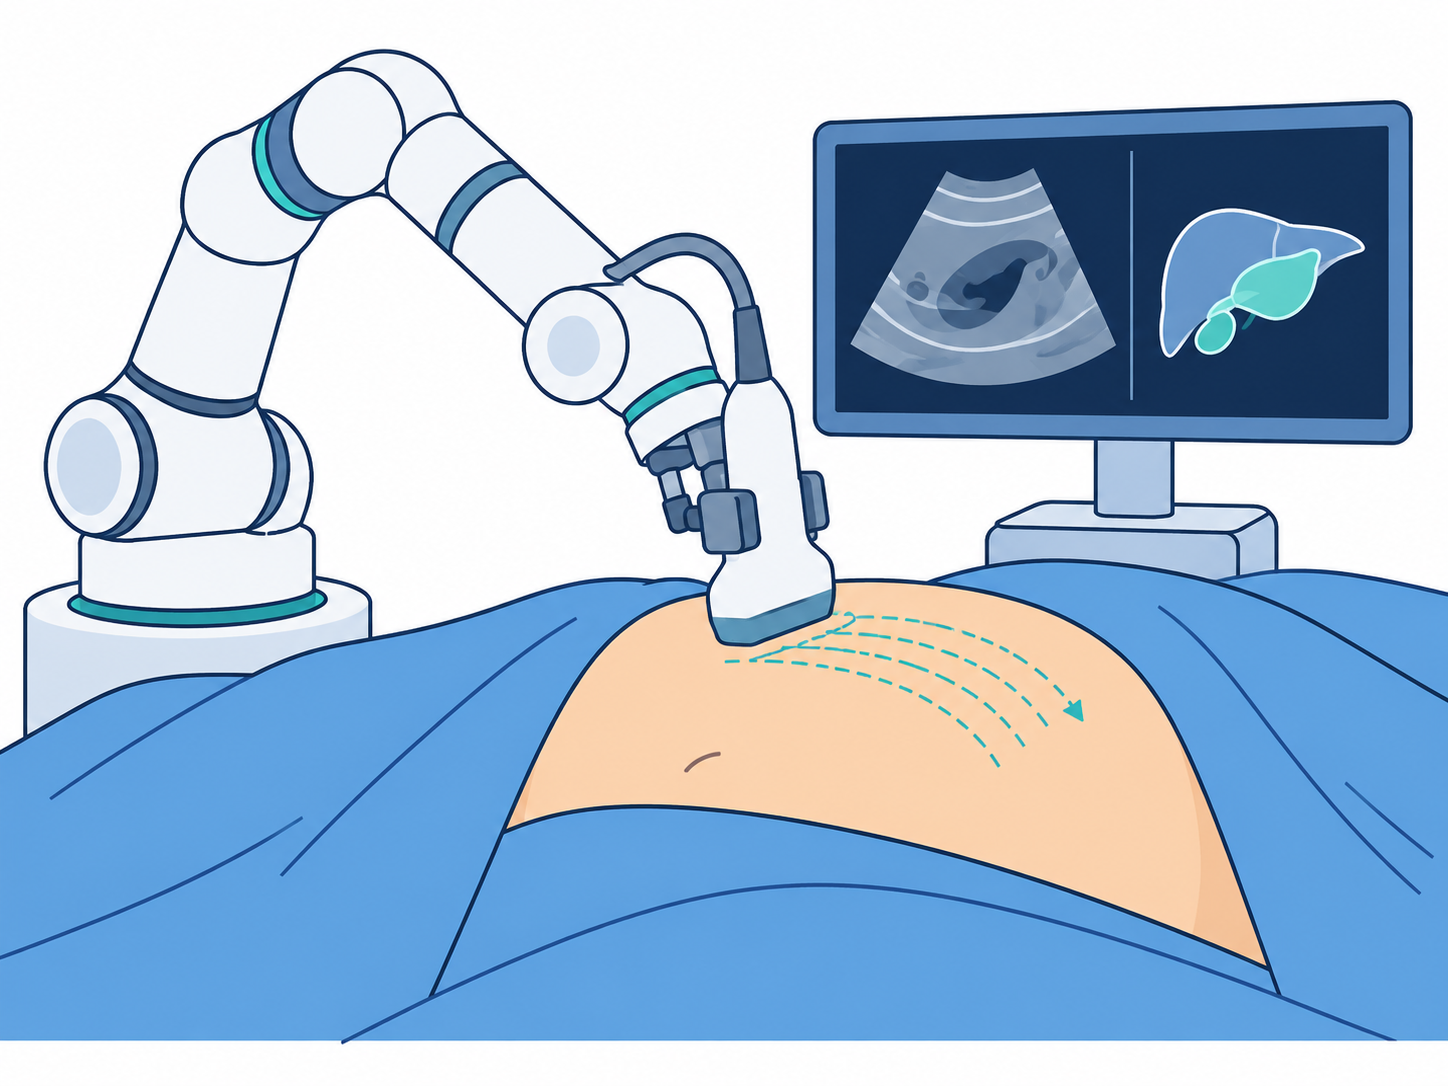
Developing a hierarchical vision-language-action framework with a VLM planner and an imitation-learning 6-DOF controller. Synchronized ultrasound, RGB-D, robot kinematics, and expert narration support learning how to scan; probe-pose-conditioned 3D organ reconstruction helps interpret the scanning procedure.
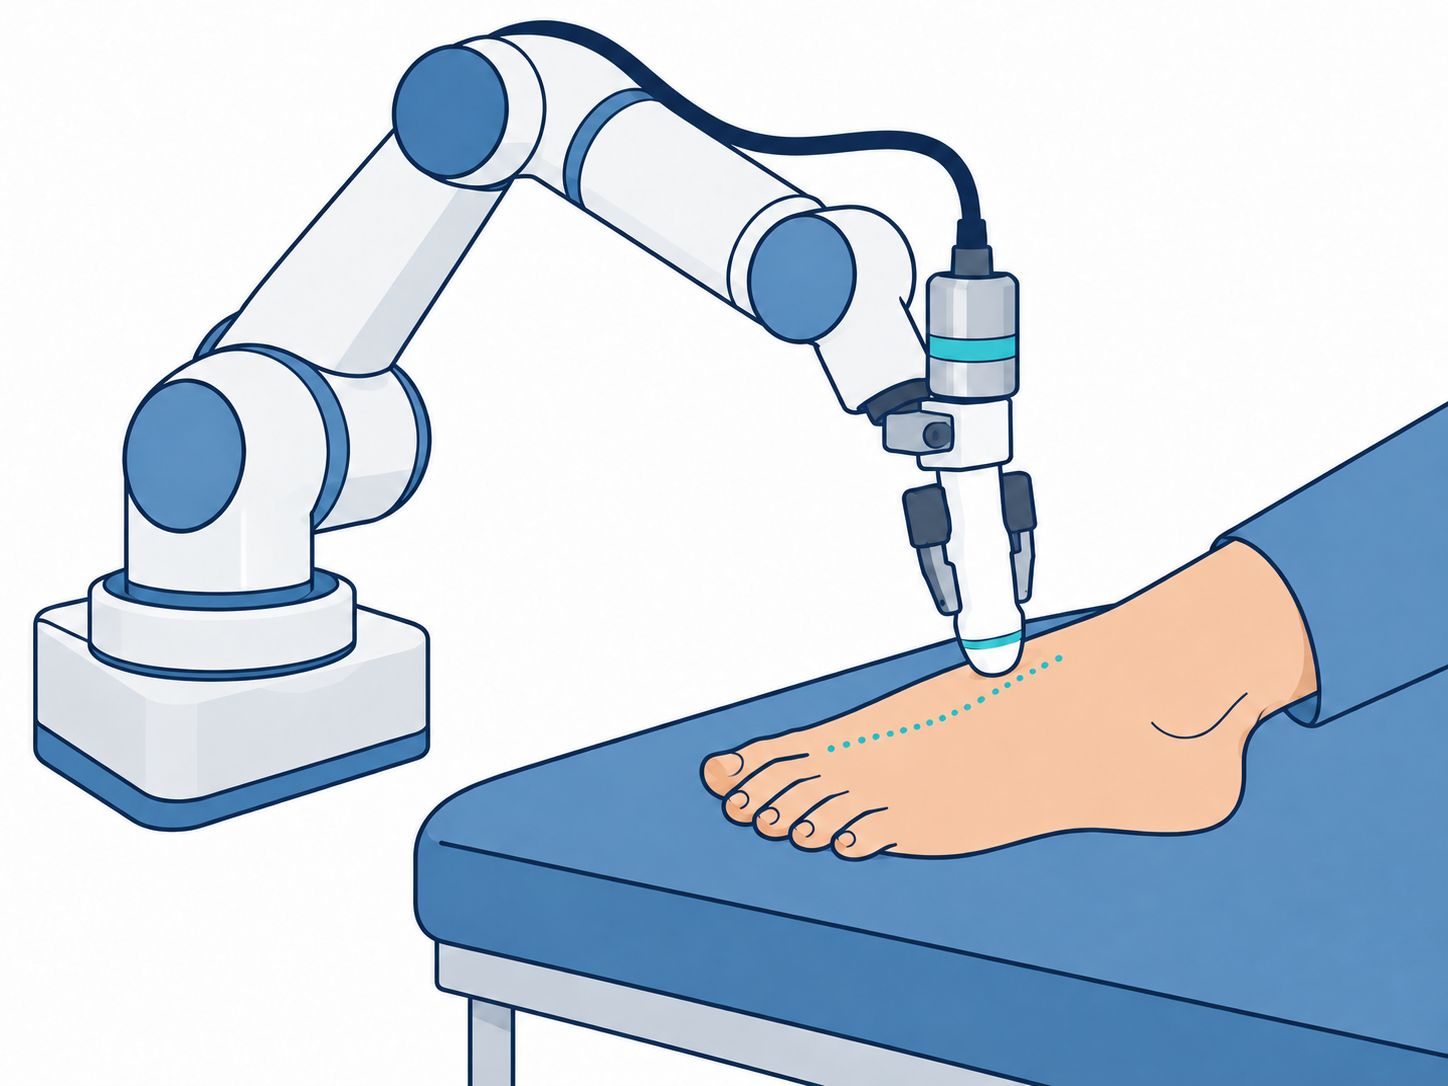
Developing robotic pedal Doppler assessment using geometric sweep motions over an estimated foot surface and a custom probe-mounted pressure sensor. The project studies how surface geometry and contact feedback can guide probe placement during a physical examination.
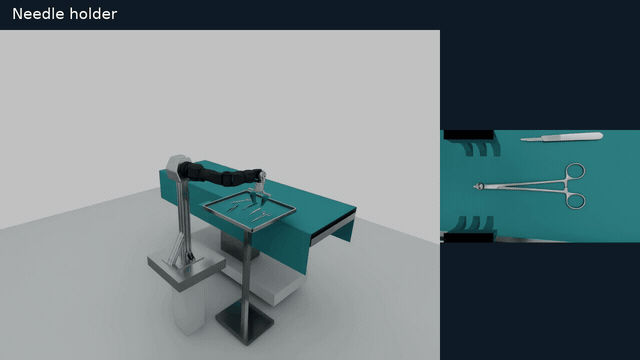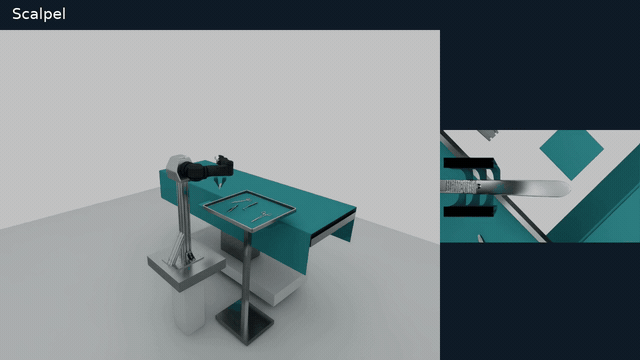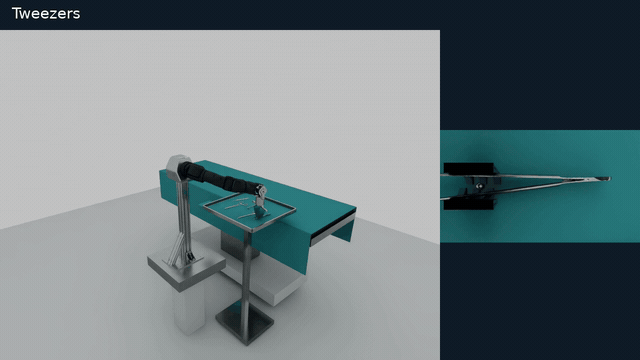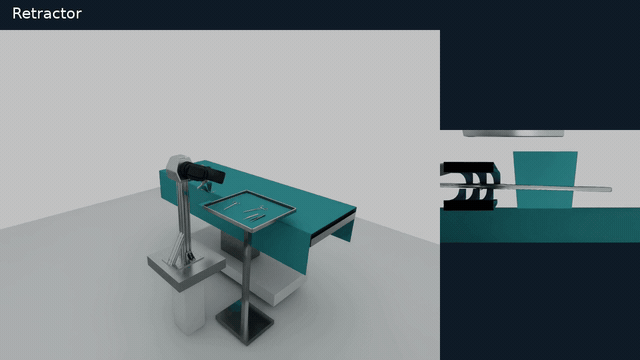
A surgical robotics project designed to anticipate instrument needs, pick up tools from a tray using a custom soft gripper, and present them handle-first to the surgeon. Simulation-generated demonstrations support training a vision-based policy to select and retrieve the requested instrument.
Deformable registration · Synthetic training data · Anatomical supervision
Developed a semi-supervised, segmentation-aware motion-correction method for in-vivo two-photon calcium imaging. Building on VoxelMorph and SynthMorph, the approach uses synthetic neuron images and auxiliary segmentation supervision to align frames while preserving neuron shapes and locations, supporting downstream neural activity analysis with limited real training data.
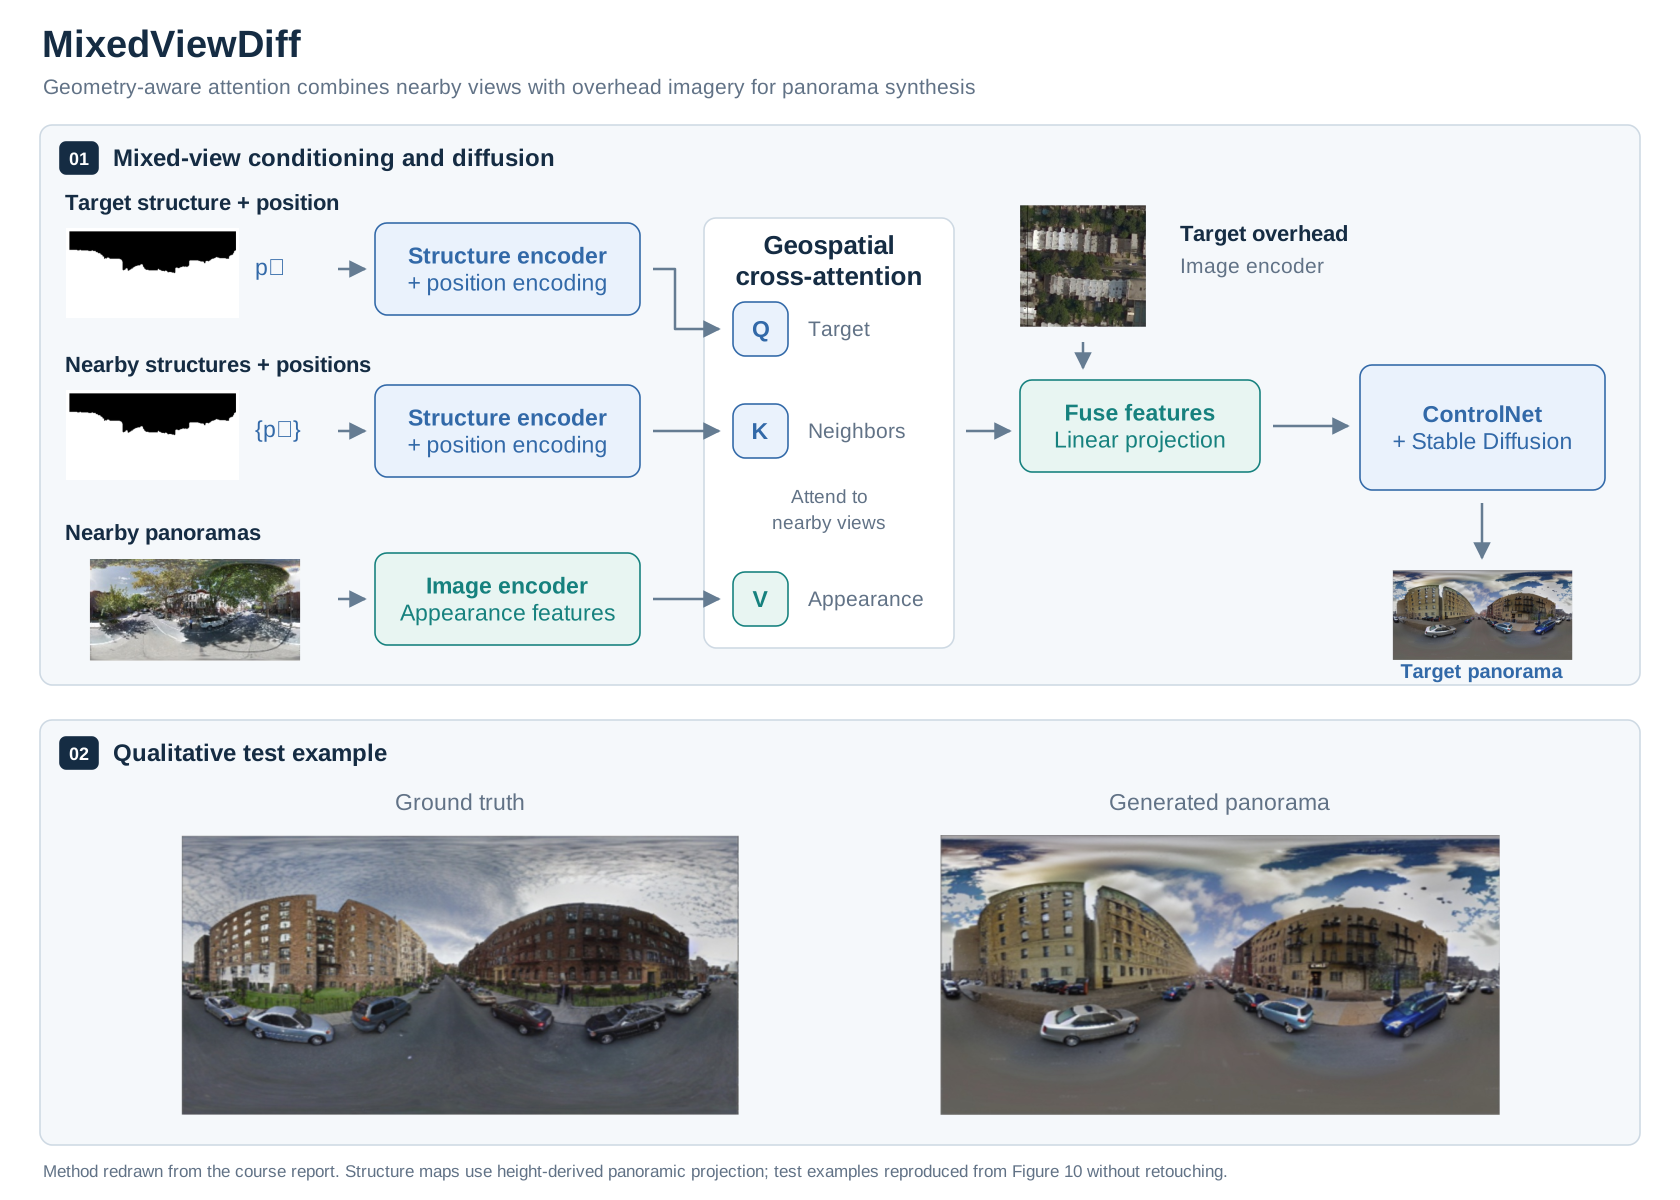
Synthesizing street-view panoramas from overhead imagery and nearby views. Height-derived structure maps and NeRF-style positional encoding guide geospatial cross-attention, combining scene geometry with appearance features to condition ControlNet and Stable Diffusion.
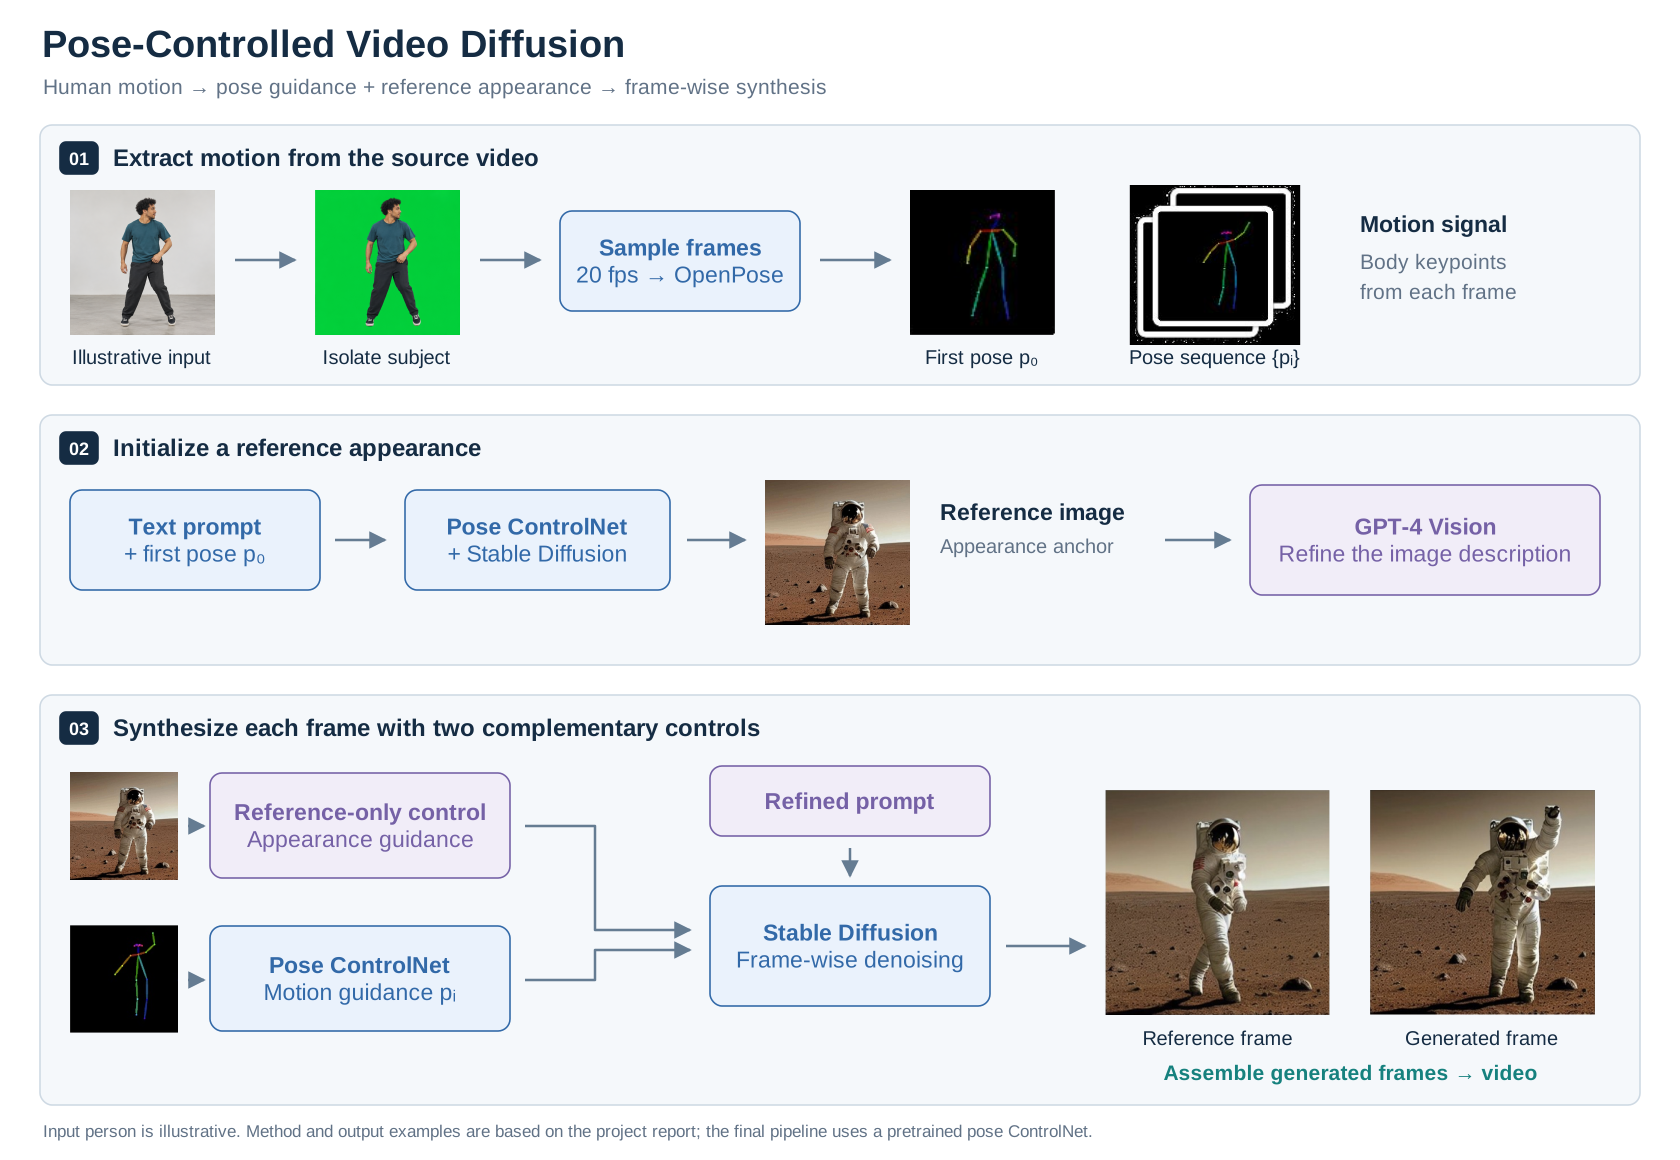
A Stable Diffusion pipeline that combines OpenPose guidance with reference-only appearance control for frame-wise video generation. The project explores pose ControlNet training and uses a pretrained pose controller in the final pipeline to transfer human motion while encouraging visual consistency.